Course B — Urban Mobility: Designing an SoS with CADL × SUMO
⬅ Back to Course A → Course A — Robot Delivery
Audience: Students who have completed the main hands-on textbook (CADL/SoS-DSL basics).
Time: 60–90 minutes.
You will leave with: A
mobility_sos.cadldescribing a taxi-fleet SoS that you have read and edited yourself, a SUMO simulation that actually runs, and a report that checks the simulation results against theguaranteeclauses of your CADL contract.
0. What this tutorial demonstrates
The main textbook used a robot-delivery SoS as the running example and generated Unity C#. This tutorial swaps both axes:
- Domain: urban mobility (taxis + passengers + a matching platform)
- Target runtime: SUMO (Simulation of Urban MObility)
The CADL/SoS-DSL syntax is unchanged — that is the whole point.
mobility_sos.cadl
       │
       ├─ cadl check                    ← type-check
       ├─ cadl sim-ir   ─► IR JSON
       │                       │
       │                       ├─► cadl-explorer (Lifecycle View)
       │                       │
       │                       └─► cadl_to_sumo.py    ← ★ codegen
       │                              ├─► SUMO sumocfg
       │                              └─► contract constraints JSON
       │
       └─ (demand CSV) ─► generate_sumo_routes.py
                                  ↓
                          SUMO ─► tripinfo.xml
                                  ↓
                          analyze_results.py (guarantee check)
                                  ↓
                       Iterate: revise CADL guarantees / deadlines
The reference implementation lives in the mobility-sos-exercise repository.
mobility-sos-exercise is not publicly available at present. The commands below assume you have been given access to it; without it, this page can still be read as a worked example of applying CADL to a mobility SoS.
1. Setup
Same as the main textbook for cadl_repo and cadl-explorer.
The new requirement is SUMO:
# The exercise repository is not publicly available at present.
# Place the copy you were given at ~/program/mobility-sos-exercise.
cd ~/program

# Exercise venv
cd mobility-sos-exercise
python3 -m venv .venv
source .venv/bin/activate
python3 -m pip install --upgrade pip
pip install -r requirements.txt

# SUMO (pip is the simplest cross-platform way)
pip install eclipse-sumo

# CADL compiler: install the clone from Course A into this venv,
# so that `cadl` and the exercise scripts run in the same shell
pip install -e ~/program/cadl_repo
cadl --version

# cadl-explorer: same as Course A, Step 4
If
z3-solverfails to build duringpip install -e ~/program/cadl_repo, fall back topip install --no-deps -e ~/program/cadl_repofollowed bypip install lark pyyaml. This tutorial only needscadl checkandcadl sim-ir, neither of which uses Z3.
2. Read the structure (5 min)
Open cadl/mobility_sos.cadl and look at the actors: inside the sos: block (excerpt):
sos:
  name: "MobilitySoS"
  type: Acknowledged
  actors:
    - id: PLATFORM
      autonomy: low                # central matching authority
    - id: "TAXI[1..N]"
      autonomy: high               # self-interested fleet
    - id: "PASSENGER[1..M]"
      autonomy: medium             # service requesters
How to read it: the platform is the central coordinator and has little freedom to act on its own (autonomy: low);
the taxis are self-interested agents with high autonomy; passengers issue requests and decide whether to board.
The same Acknowledged SoS type as the robot-delivery example.
So far you have read only the structure (the actors). Check the file, and print how much of the contract's normative part the IR carries:
cd ~/program/mobility-sos-exercise
cadl check  cadl/mobility_sos.cadl        # → Type check passed: cadl/mobility_sos.cadl
cadl sim-ir cadl/mobility_sos.cadl --format json \
   | python3 -c "import sys, json; c=json.load(sys.stdin)['institution']['contracts'][0]; print('lifecycle =', 'present' if c['lifecycle'] else None, '/ monitors =', len(c['monitors']))"
The file you are reading is the complete specification: its contract already carries the
lifecycle: and monitors: blocks that §3 walks through, so the command should report a lifecycle.
To see what the structure alone would give, make a scratch copy, delete the lifecycle: and
monitors: blocks from it, and run the same two commands on the copy: cadl check still passes, but
the IR has "lifecycle": null and no monitors, and cadl-explorer shows no diagram: only a warning that the
contract does not declare a lifecycle: section, and a note that it declares no monitors.
That gap — structure alone cannot express deadlines, violations, or consequences — is what the blocks you read in §3 fill.
3. Read the contract (10 min)
The contract in the same file (an excerpt: the assume: and incentives: blocks, the transitions after accept, and the
monitors waiting_too_long and detour_guard are omitted; the # ... at the end of each list
stands for its omitted entries; comments are removed and on_violation: / on_match: are
written in flow style):
contracts:
  - id: RIDE_SLA
    parties: [PLATFORM, "TAXI[*]", "PASSENGER[*]"]
    guarantee:
      - "waiting_time <= 300s"
      - "ride_time <= 1800s"
    lifecycle:
      states: [Requested, Matched, Accepted, PickedUp, Delivered,
               Violated, Cancelled, Terminated]
      initial: Requested
      terminal: [Delivered, Violated, Cancelled, Terminated]
      transitions:
        - id: match
          from: Requested
          to:   Matched
          on:   "PLATFORM -> TAXI[i] : match_assignment"
          deadline: 30s
          on_violation: { transition: Violated, severity: Major }
        - id: accept
          from: Matched
          to:   Accepted
          on:   "TAXI[i] -> PLATFORM : ack(accepted)"
          deadline: 5s
          on_violation: { transition: Violated, severity: Major }
        # ...
    monitors:
      - id: low_battery_guard
        observe: "TAXI[i].battery"
        sampling: periodic(500ms)
        rule: "TAXI[i].battery < 15 AND state == Accepted"
        on_match: { transition: Violated, severity: Critical }
      # ...
Exercise 3-1
One lifecycle instance corresponds to one ride request. Answer the following.
- If the platform fails to dispatch within 31 seconds, what state does the contract enter?
- Whose responsibility is the
acceptdeadline? - State, in one sentence, when
low_battery_guardfires.
4. Visualize (10 min) — 🔍 Visualization Checkpoint 1 (post-DSL)
In §3 you read the lifecycle: and monitors: blocks of the CADL source.
Because the file contains them, cadl-explorer renders a meaningful picture.
cd ~/program/mobility-sos-exercise
cadl check  cadl/mobility_sos.cadl
cadl sim-ir cadl/mobility_sos.cadl --format json > cadl/mobility_sos.ir.json

cd ~/program/cadl-explorer
streamlit run app.py
# Browser opens at http://localhost:8501
# Sidebar → "Contract Lifecycle" → drag mobility_sos.ir.json into the uploader
You should see something like:
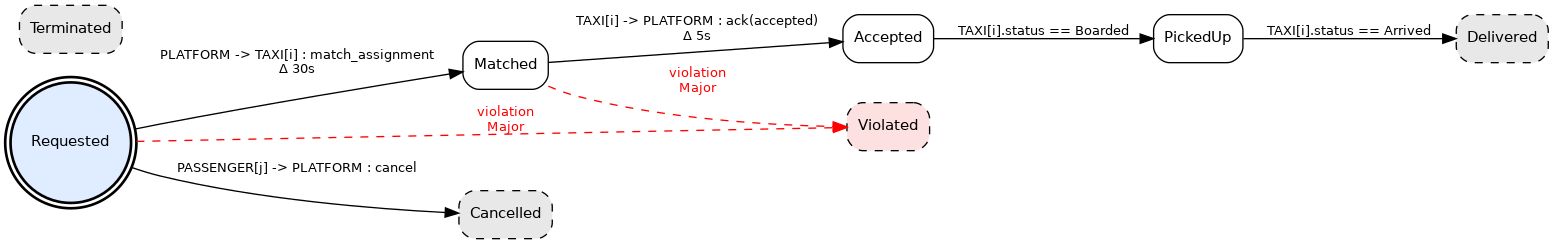
| Visual | Meaning |
|---|---|
Double circle = Requested | initial state |
Dashed grey = Delivered/Cancelled/Terminated | normal terminals |
Dashed pink = Violated | violation terminal |
Solid edge with Δ 30s / Δ 5s | deadline-bearing transitions |
Red dashed edge labelled violation / Major (two lines) | forced move to the on_violation target state |
Terminated stands alone in the diagram: the contract declares it as a terminal state, but no transition leads to it. If you open mobility_sos.cadl on the Designer page, the same fact is reported as a Lifecycle warning (State 'Terminated' cannot be reached from the initial state 'Requested'). cadl check passes regardless.
You will run edit CADL → cadl sim-ir → reload cadl-explorer at every milestone:
after reading the structure, after reading the contract, after codegen, after the simulation, after revising the contract.
The whole point of the tutorial is to internalize that the picture changes in lockstep with the code.
Exercise 4-1
In cadl/mobility_sos.cadl, change the match deadline from 30s to 60s, regenerate the IR,
and upload it again. The edge label should change from Δ 30s to Δ 60s.
Once verified, revert it back to 30s before continuing (later sections assume 30s).
5. Generate SUMO code (10 min)
scripts/cadl_to_sumo.py is the SUMO counterpart to
cadl codegen --target unity-csharp: it consumes the IR JSON and
emits SUMO configuration plus a contract-constraints JSON.
cd ~/program/mobility-sos-exercise
python scripts/cadl_to_sumo.py
Example output (excerpt; the scripts print their progress messages in Japanese):
[1/4] CADL.environment 検証
  [OK] grid_size=5 は SUMO ネットワークと一致。
[2/4] contracts → constraints 抽出
  - contract RIDE_SLA
      guarantees: 2
        waiting_time   <= 300.0s
        ride_time      <= 1800.0s
      deadlines : 2
        match      30.0s (violation→Violated, sev=Major)
        accept     5.0s (violation→Violated, sev=Major)
      monitors  : 3
[3/4] sumocfg 生成 (CADL.time_step_ms / 終端を反映)
  ✓ step-length = 1.0s
  ✓ end         = 4920s
Produces:
sumo/config/midtown.cadl.sumocfg—step-lengthfromenvironment.time_step_ms,end= the lastdepartinsumo/routes/midtown.rou.xml+ the larger of 1800 s and theride_timeguarantee + 60 s (3060 + 1800 + 60 = 4920 with the sample data). If the route file does not exist yet,endis 3600 s; §6 re-runs this script aftergenerate_sumo_routes.py, beforerun_sumo.py, which gives 4920 s. A tighterride_time(as in §8) does not shortenend.sumo/cadl_constraints.json— the contract conditions (guarantees / deadlines / monitors) thatanalyze_results.pyreads.
cadl_to_sumo.py only reads the IR and writes SUMO config files; it never
modifies cadl/mobility_sos.cadl. The lifecycle: and monitors: blocks are
byte-for-byte identical to what they were in §3.
Reload cadl-explorer now and you should see the exact same picture as in §4.
That invariance is what lets us treat CADL as the single source of truth: target-specific generators consume the spec without mutating it.
6. Run SUMO (10 min)
# Check the sample demand CSV
python scripts/prepare_sample_data.py

# Build the SUMO network (one time)
netconvert -c sumo/network/midtown.netccfg

# CSV → route file
python scripts/generate_sumo_routes.py

# Regenerate the sumocfg now that the route file exists (end = 4920 s)
python scripts/cadl_to_sumo.py

# Run SUMO (picks the CADL-derived sumocfg)
python scripts/run_sumo.py            # headless
# python scripts/run_sumo.py --gui    # with visualization
This populates results/tripinfo.xml and results/summary.xml.
The headless run needs nothing beyond the eclipse-sumo package. --gui starts sumo-gui, which is an X11 application: on macOS it needs XQuartz installed and running, and without it the run stops with FXApp::openDisplay: unable to open display. The same error appears right after installing XQuartz, until you log out and back in; to continue without doing so, start XQuartz (open -a XQuartz) and run export DISPLAY=:0 in the terminal first. In the SUMO window, press the play button to start the simulation. The rest of this course uses only the headless results.
7. Check the results against the contract (10 min)
python scripts/analyze_results.py
Example output (excerpt; the header line is printed in Japanese):
=== CADL 契約 (cadl_constraints.json) との遵守チェック ===

  contract: RIDE_SLA
    -- guarantees --
      [OK          ] waiting_time <= 300s  (tripinfo.waitingTime)
      [OK          ] ride_time <= 1800s  (tripinfo.duration)
    -- deadlines (lifecycle) --
      [SKIP        ] match      ≤ 30.0s  (not-evaluated (matching/accept events not modeled in SUMO yet))
      [SKIP        ] accept     ≤ 5.0s  (not-evaluated (matching/accept events not modeled in SUMO yet))
    -- monitors --
      [SKIP        ] waiting_too_long      (not-evaluated (observed attribute not exported by SUMO))
      [SKIP        ] low_battery_guard     (not-evaluated (observed attribute not exported by SUMO))
      [SKIP        ] detour_guard          (not-evaluated (observed attribute not exported by SUMO))
What is actually checked here is the two guarantee clauses only; the deadlines and the three monitors are listed but not evaluated:
- Guarantees are evaluated against
tripinfo.xml.ride_timemaps directly totripinfo.duration.waiting_timeis compared withtripinfo.waitingTime, which is only a stand-in: it is the time a vehicle spent standing still during its trip, not the time a passenger waited for a taxi. In this pipeline each CSV row inserts one vehicle at the pickup point at the pickup time, so no passenger ever waits, and the value is 0 s for all 30 trips. This[OK]therefore holds by construction. - Deadlines for matching/accept events are not modeled in SUMO yet — flagged SKIP.
- Monitors observe per-passenger
waiting_timewhileMatched,battery, androute_deviation_ratio, none of which SUMO exports — flagged SKIP.
Each line of analyze_results.py's output traces back to something in cadl-explorer's diagram.
With the explorer open beside the terminal, walk through the correspondence:
analyze_results.py line | Where it lives in cadl-explorer |
|---|---|
[OK] waiting_time <= 300s | Not in the graph (a numeric guarantee, evaluated post-hoc) |
[OK] ride_time <= 1800s | Same as above |
[SKIP] match ≤ 30.0s | The Δ 30s label on the Requested → Matched edge |
[SKIP] accept ≤ 5.0s | The Δ 5s label on the Matched → Accepted edge |
[SKIP] waiting_too_long / low_battery_guard / detour_guard | First, second and third rows of the Monitors table |
SKIP is not a failure — it simply reports that SUMO has no observable for that signal.
A stretch goal in §9 walks through closing one of these gaps via TraCI.
8. Sensitivity analysis: edit the contract, re-evaluate (10 min)
This is the punchline. Edit a CADL guarantee, regenerate the IR, and the existing simulation result is re-evaluated against the new contract — without re-running SUMO.
# Rewrite ride_time 1800s → 100s (for the experiment)
sed -i.bak 's|ride_time <= 1800s|ride_time <= 100s|' cadl/mobility_sos.cadl

# Regenerate the IR (no need to re-run the simulation)
cadl sim-ir cadl/mobility_sos.cadl --format json > cadl/mobility_sos.ir.json
python scripts/cadl_to_sumo.py

# Re-evaluate the existing SUMO results
python scripts/analyze_results.py | grep -E "OK|VIOLATED"
Output (12 violations with SUMO 1.28.0; the violation count and the taxis listed vary with the random seed and your SUMO
version — what matters is the pattern: waiting_time stays OK while ride_time turns
VIOLATED):
      [OK          ] waiting_time <= 300s  (tripinfo.waitingTime)
      [VIOLATED (12)] ride_time <= 100s  (tripinfo.duration  e.g. ['taxi_8', 'taxi_9', 'taxi_10', 'taxi_11', 'taxi_14'])
OK: 分析完了。
The last line is the script's closing message ("analysis complete"); it matches the grep pattern because it starts with OK.
Reload cadl-explorer before running analyze_results.py.
The change you just made touches only a guarantee value (ride_time <= 1800s → 100s).
You did not touch lifecycle: or monitors:, so the state-machine diagram itself is
identical to §4 — same states, same transitions, same Δ labels.
To change the diagram you would have to edit transitions: (you did exactly that in Exercise 4-1).
The reason this checkpoint still matters is that, after editing the CADL source,
you should consciously go back to the browser and see that the same spec
that drives the diagram also drives analyze_results.py's verdict. That single-source
correspondence is the whole goal of this tutorial:
  CADL source (mobility_sos.cadl)
        │
        ├── Picture (cadl-explorer)        ← visual understanding
        ├── Execution (SUMO)                ← dynamic behavior
        └── Verdict (analyze_results.py)    ← guarantee check
That round-trip is the SoS-design feedback loop CADL is meant to enable.
When you're done, restore the original guarantee:
mv cadl/mobility_sos.cadl.bak cadl/mobility_sos.cadl
cadl sim-ir cadl/mobility_sos.cadl --format json > cadl/mobility_sos.ir.json
python scripts/cadl_to_sumo.py
9. Stretch goals
| Task | Hint |
|---|---|
Tighten the match deadline 30s→10s; how many trips realistically meet it? | SUMO has no match event (one CSV row is one vehicle), and cadl_to_sumo.py only reads the IR, so the line stays [SKIP]. Extend analyze_results.py to use departDelay in tripinfo.xml as a proxy. With the sample data it is 0 s for all 30 trips, so first decide what a match event should be. |
Change num_taxis from 10 to 5 and find out whether anything changes. | Nothing in the SUMO pipeline consumes num_taxis (demand comes from the CSV, one vehicle per row): the 30 <tripinfo> rows of tripinfo.xml are identical after the change (only the header comment with the generation time differs). Use the running time series in summary.xml (it peaks at 2 with the sample data) to argue what fleet size this demand needs, and what would have to be modelled for a capacity violation to appear. |
Add a new monitor surge_pricing_guard and follow it through the toolchain. | Add it under monitors: and regenerate the IR. Confirm that it reaches the IR (4 monitors), the Monitors table in cadl-explorer and the [SKIP] list of analyze_results.py. Monitor rules are not evaluated by this pipeline, so there is no trigger pattern to observe yet. |
| A/B visual diff: compare the before and after designs. | In cadl-explorer, open the .cadl file on the Designer page, save a version under Versions, open the revised file and compare the two there: under Compare two designs, choose your saved version as A — baseline (the default may be a bundled example) and the current design as B (structured diff and source diff). To see two lifecycle diagrams side by side, open the Contract Lifecycle page in two browser tabs and upload one IR in each; a second instance on another port is not needed. |
Close one of the [SKIP] gaps by reading the relevant SUMO signal via TraCI: measure the match deadline. | pip install eclipse-sumo does not make traci importable: run pip install traci, or add os.path.join(sumo.SUMO_HOME, "tools") to sys.path after import sumo (the shell variable $SUMO_HOME is not set by the pip install). Read traci.vehicle.getDeparture(vehID) (or traci.simulation.getDepartedIDList()) and compare it with the CSV's pickup_time. This measures insertion delay — a proxy for match, 0 s in the sample data — not a modelled match event. |
Summary
- Same CADL/SoS-DSL syntax; different domain (mobility vs robot delivery) and different runtime (SUMO vs Unity C#).
- The contract's deadlines / guarantees / monitors live in one place, the CADL source, and reach each
tool through the IR that
cadl sim-iremits. How much of them a given runtime can evaluate differs: in this course the SUMO pipeline evaluates theguaranteeclauses only, and reports the deadlines and monitors as[SKIP]because SUMO has no observable for them. - Editing a CADL guarantee and re-running the analysis re-evaluates the existing results without re-simulating — a cheap, fast feedback loop for SoS design.
References
- Main textbook (robot delivery):
main-textbook.md - Exercises:
exercises.md - SoS-DSL spec: cadl-spec Appendix E
- SUMO project: https://eclipse.dev/sumo/