-
2025 Domestic Real-time
Collision Avoidance System for Rowing Competitions Using Smartphones Shunsuke Oba, Yutaka Matsubara, Hiroaki Takada
ETNET 2025, Okinoerabu
-
2025 Award Real-time
Best Paper Award for GLACI: Arbitrary Code Instrumentation Tool for OpenGL (awarded May 2025) Shotaro Tsuboi, Yixiao Li, Yutaka Matsubara, Hiroaki Takada
The 20th International Conference on Systems (ICONS 2025), Nice, France, May 2025
-
2025 Award Real-time
Best Young Presentation Award for Real-Time Evaluation of a Full-Scratch Linux-Compatible Unikernel (awarded Mar 2025) Yoshifumi Shu, Yutaka Matsubara, Ryoma Hiraoka, Ryosuke Yamamoto, Hitoshi Yamamoto, Shingo Oidate, Hiroaki Takada
166th IPSJ OS Workshop
-
2024 Intl. conf. Real-time
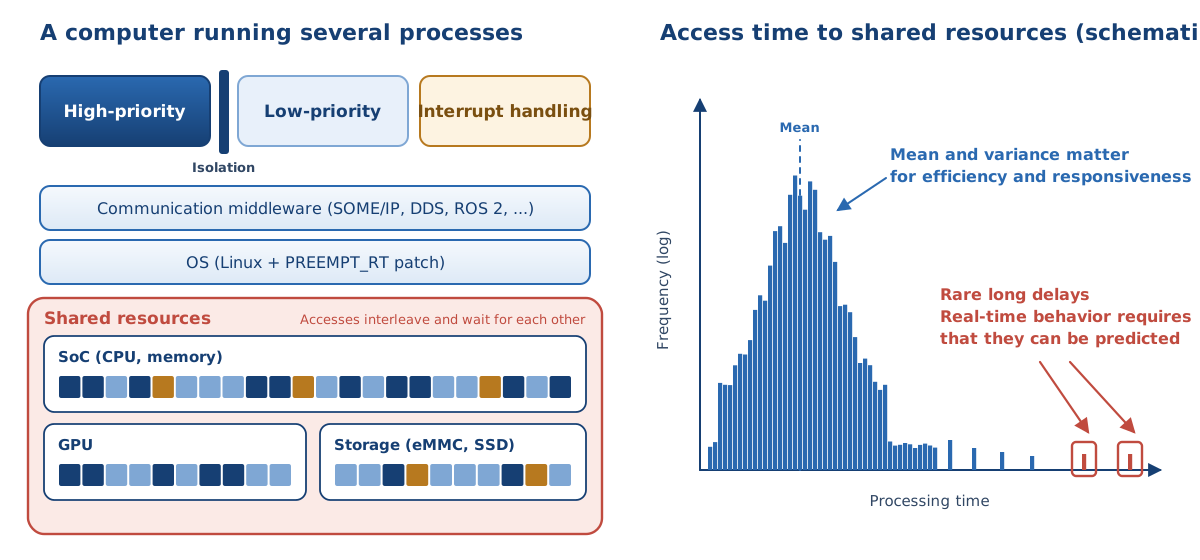
Monitor and Analyze Rare ROS2 Performance Issues with A Unified Tracing Framework Yixiao Li, Yutaka Matsubara, Hiroaki Takada, Satoru Funahashi, Hiroki Kawashima
The 6th International Workshop on Software Science and Engineering (WSSE 2024), Kyoto, Aug 2024
This paper presents a unified tracing framework to monitor and analyze rare performance problems in ROS 2, a widely used robot software platform. The framework records events across the software stack in a unified way, so developers can trace back what happened when a rare slowdown occurs.
-
2024 Domestic Real-time
Design and Implementation of Software Fault Countermeasures for Lingua Franca Yoshinori Terazawa, Akihito Iwai, Wenhung Kevin Huang, Yutaka Matsubara
IPSJ EMB-67, Vol.2024-EMB-67 No.1, pp.1-8
-
2024 Domestic Real-time
Real-Time Evaluation of Storage Devices in Linux Shinnosuke Koshiba, Yutaka Matsubara, Yuichi Nakao, Hiroaki Takada
163rd System Software and Operating Systems Workshop, Okinawa, No.8, pp.1-8
-
2024 Domestic Real-time
Evaluation on the Impact of HTB on Network Stack Latency and Real-time Performance using eBPF Haohong Xie, Yutaka Matsubara, Toshikazu Kato, Hitoshi Yamamoto, Shingo Oidate, Hiroaki Takada
ETNET 2024, Iki
-
2024 Poster Real-time
EUKL: A Prototype of a Linux-Based Unikernel for Resource-Constrained Embedded Systems Yoshifumi Shu, Yutaka Matsubara, Yixiao Li, Hiroaki Takada
ACM SIGOPS Asia-Pacific Workshop on Systems 2024, Kyoto
-
2024 Award Real-time
TOPPERS of the Year 2024 Activity Division: Support for ET Robocon (awarded Nov 2024) Yoshifumi Shu, Yixiao Li, Yutaka Matsubara
TOPPERS Project
-
2023 Article Real-time
Automotive Control Systems as Distributed Real-Time Systems Hiroaki Takada, Yutaka Matsubara
Systems, Control and Information (ISCIE), Vol.67, No.12
A review article explaining automotive control systems from the viewpoint of distributed real-time systems, where many computers must cooperate under strict timing constraints. It describes how the many electronic control units connected by in-vehicle networks must exchange data and finish computations on time.
-
2023 Journal Real-time
A Performance Evaluation of Embedded Multi-core Mixed-criticality System Based on PREEMPT_RT Linux Yixiao Li, Yutaka Matsubara, Hiroaki Takada, Kenji Suzuki, Hideaki Murata
Journal of Information Processing, Vol.31, pp.78-87
This paper evaluates the real-time performance of PREEMPT_RT Linux when running tasks of different criticality levels together on an embedded multi-core processor. The evaluation examines how critical and non-critical tasks interfere with each other when they share cores. The results inform decisions about consolidating functions onto one computer.
Link
-
2023 Domestic Real-time
Evaluation of Network Bandwidth Guarantee with HTB Traffic Control Haohong Xie, Yutaka Matsubara, Toshikazu Kato, Hitoshi Yamamoto, Takehisa Mizuguchi, Hiroaki Takada
ETNET 2023, Tokunoshima
Link
-
2023 Domestic Real-time
Evaluation of Low-Level Runtimes in Container Virtualization Ryota Nishimura, Yutaka Matsubara, Hiroaki Takada
ETNET 2023, Tokunoshima
-
2022 Journal Real-timeVerification
Design and Implementation of RTOS-Aware Control-Flow Integrity Mechanism for Microcontroller-Based Systems Tomoaki Kawada, Shinya Honda, Yutaka Matsubara, Hiroaki Takada
Computer Software, Vol.39, No.2
This paper designs a control-flow integrity mechanism, a defense that stops attackers from hijacking program execution, tailored to RTOS-based microcontroller systems. The mechanism is designed to keep protecting the system even when the RTOS switches tasks and handles interrupts, situations that ordinary CFI designs do not consider. This strengthens small embedded devices that are hard to patch after deployment.
Link
-
2022 Domestic Real-time
SPIKE-RT: A Real-Time Software Platform for LEGO SPIKE Prime Yoshifumi Shu, Yixiao Li, Yutaka Matsubara, Shinya Honda
IPSJ EMB-61, Vol.2022-EMB-61 No.11, pp.1-6
Link
-
2022 Domestic Real-time
Visual Modeling and Design Methodology for AUTOSAR Platform Using MBSE Tools Mitsutaka Takada, Ryosuke Takahashi, Yutaka Matsubara
IPSJ EMB-61, Yokohama
-
2022 Domestic Real-time
Improving Responsiveness by Guaranteeing Storage I/O Bandwidth in the BFQ Scheduler Hiroki Hasegawa, Yutaka Matsubara, Toshikazu Kato, Hitoshi Yamamoto, Takehisa Mizuguchi, Hiroaki Takada
ETNET 2022, Online
-
2022 Domestic Real-time
Extending cgroup for Flexible CPU Resource Accounting Eisuke Matsushita, Yutaka Matsubara, Hiroaki Takada
ETNET 2022, Online
-
2021 Domestic Real-time
Shared Hardware Analysis Method in Hypervisors Kenta Suzuki, Yutaka Matsubara, Tomokazu Moriya, Kenji Mototani, Hideyuki Iwakiri, Hiroaki Takada
ETNET 2021, Online
Link
-
2021 Domestic Real-time
Storage Access Analysis Method from Applications Hiroki Hasegawa, Yutaka Matsubara, Toshikazu Kato, Hitoshi Yamamoto, Hiroaki Takada
ETNET 2021, Online
Link
-
2021 Award Real-time
Best Poster Bronze Award for Visual Design Tool for AUTOSAR Vehicle-Level Specifications (awarded Sep 2021) Mitsutaka Takada, Ryosuke Takahashi, Yutaka Matsubara
SWEST 23
-
2020 Journal Real-timeVerification
TZmCFI: RTOS-Aware Control-Flow Integrity Using TrustZone for Armv8-M Tomoaki Kawada, Shinya Honda, Yutaka Matsubara, Hiroaki Takada
International Journal of Parallel Programming, Vol.49, pp.136-150
This paper presents TZmCFI, a control-flow integrity mechanism for small Arm microcontrollers that uses the TrustZone security feature and works correctly with an RTOS. TrustZone provides an isolated area that attackers cannot tamper with, and the mechanism keeps its protection consistent across task switches and interrupts. This defends small devices that lack the hardware protections of larger computers.
Link
-
2020 Journal Real-time
esprof: A Generic Profiling Infrastructure for Multi/Many-Core Embedded Systems Yixiao Li, Yutaka Matsubara, Hiroaki Takada
Computer Software, Vol.37, No.1, pp.1_54-1_67
This paper presents esprof, a general-purpose profiling infrastructure for measuring and analyzing the behavior of multi- and many-core embedded software. It offers a common way to insert measurement points and collect events across different OSes and hardware, instead of building ad-hoc tools each time.
Link
-
2020 Domestic Real-time
Software Design Method for Intelligent Automotive Control Systems Keisuke Ozawa, Shinya Honda, Yutaka Matsubara, Hiroaki Takada, Toshikazu Kato, Hitoshi Yamamoto
ETNET 2020, Yoron
Link
-
2020 Domestic Real-time
Evaluation of Adaptive Cruise Control Using a Virtual Environment Simulator for Automated Driving Kazuki Imai, Koji Hoshikawa, Yuka Hashimoto, Miki Yasumura, Kuniaki Goya, Noritaka Ota, Yutaka Matsubara
IPSJ Research Report ETNET 2020, Yoron
Link
-
2019 Journal Real-time
Energy-Efficient Intra-Task DVFS Scheduling Using Linear Programming Formulation Yang Qin, Gang Zeng, Ryo Kurachi, Yixiao Li, Yutaka Matsubara, Hiroaki Takada
IEEE Access, Vol.7, pp.30536-30547
This paper uses linear programming to decide when to change processor speed within a task (intra-task DVFS) so that energy is saved without missing deadlines. The task is divided into segments and an optimization determines the best speed for each, exploiting the fact that slower execution consumes less energy. Deadlines are treated as constraints, so real-time guarantees are preserved.
Link
-
2019 Journal Real-time
Energy-Aware Task Allocation for Heterogeneous Multiprocessor Systems by Using Integer Linear Programming Yang Qin, Gang Zeng, Ryo Kurachi, Yutaka Matsubara, Hiroaki Takada
Journal of Information Processing, Vol.27, pp.136-148
This paper formulates energy-aware task allocation on heterogeneous multiprocessors as an integer linear programming problem to minimize energy while meeting deadlines. Formulating the problem mathematically lets a solver find allocations that exploit the different speed and power characteristics of each core.
Link
-
2019 Intl. conf. Real-timeVerification
Shadow Exception Stacks: Control-Flow Integrity for Asynchronous Exceptions Using TrustZone for Armv8-M Tomoaki Kawada, Shinya Honda, Yutaka Matsubara, Hiroaki Takada
IESS 2019, LNCS Vol.11937, pp.56-71, Friedrichshafen, Nov 2019
This paper proposes shadow exception stacks, which extend control-flow integrity protection to interrupt handling on Arm microcontrollers using TrustZone. Interrupts complicate control-flow protection because they can occur at any moment, and the shadow stacks record return paths safely inside TrustZone. This addresses a gap left by CFI schemes that ignore asynchronous exceptions.
-
2019 Domestic Real-time
Simulation Evaluation of IEEE 1588 Time Synchronization for In-Vehicle Networks Xiwen Chen, Yutaka Matsubara, Yasuhiro Yamazaki, Kenji Mototani, Kazuhiro Kajio, Hideyuki Iwakiri, Hiroaki Takada
ETNET 2019, Nishinoomote
-
2019 Domestic Real-time
Comparison of Inter-Application Communication Models on Embedded Software Platforms Mitsutaka Takada, Yutaka Matsubara
ETNET 2019, Nishinoomote
-
2019 Domestic Real-timeVerification
Shadow Exception Stacks: TrustZone-M Based CFI for Asynchronous Exceptions Tomoaki Kawada, Shinya Honda, Yutaka Matsubara, Hiroaki Takada
SCIS 2019, Otsu
-
2019 Award Real-time
FY2019 Software Paper Award for EV3RT: A Real-time Software Platform for LEGO Mindstorms EV3 (awarded Sep 2019) Yixiao Li, Yutaka Matsubara, Hiroaki Takada
JSSST
-
2018 Journal VerificationReal-time
IDH-CAN: A Hardware-Based ID Hopping CAN Mechanism With Enhanced Security for Automotive Real-Time Applications Wufei Wu, Ryo Kurachi, Gang Zeng, Yutaka Matsubara, Hiroaki Takada, Renfa Li, Keqin Li
IEEE Access, Vol.6, pp.54607-54623
This paper proposes IDH-CAN, a hardware mechanism that periodically changes CAN message IDs to make attacks on in-vehicle networks harder while preserving real-time behavior. Because CAN messages are normally identified by fixed IDs, hopping them deprives attackers of an easy target. Implementing the hopping in hardware keeps message timing predictable, which is essential for control systems.
Link
-
2018 Journal Real-time
Execution-variance-aware Task Allocation for Energy Minimization on the big.LITTLE Architecture Yang Qin, Gang Zeng, Ryo Kurachi, Yutaka Matsubara, Hiroaki Takada
Sustainable Computing: Informatics and Systems, Vol.20, pp.81-93
This paper allocates tasks on the big.LITTLE architecture, which combines fast and power-efficient cores, considering variations in execution time to minimize energy. Real tasks often finish earlier than their worst-case estimates, and the method exploits this slack when deciding which core runs which task. This saves energy on the kind of processors widely used in smartphones and embedded devices.
-
2018 Journal Real-time
A Comparative Analysis of RTOS and Linux Scalability on an Embedded Many-core Processor Yixiao Li, Yutaka Matsubara, Hiroaki Takada
Journal of Information Processing, Vol.26, pp.225-236
This paper compares how well an RTOS and Linux scale on an embedded many-core processor, providing data for choosing an OS for such platforms. The same measurements are run on both OSes while the number of cores increases, revealing where each design stops scaling.
Link
-
2018 Intl. conf. Real-time
Energy-Aware Task Allocation for Large Task Sets on Heterogeneous Multiprocessor Systems Yang Qin, Gang Zeng, Ryo Kurachi, Yutaka Matsubara, Hiroaki Takada
EUC 2018, pp.158-165, Bucharest, Romania, Oct 2018
This paper proposes an energy-aware method to allocate large sets of tasks on heterogeneous multiprocessors, scaling beyond exact optimization approaches. A heuristic approach finds good allocations quickly where exact optimization would take far too long. This targets realistic embedded systems with large numbers of tasks.
Link
-
2018 Domestic (reviewed) Real-timeVerification
Multitask CFI Using Arm TrustZone for Armv8-M Tomoaki Kawada, Shinya Honda, Yutaka Matsubara, Hiroaki Takada
ESS 2018 Proceedings, Gero, pp.71-74
Link
-
2018 Domestic Real-time
Applicability of ROS2 and Lightweight DDS to Embedded Systems Keisuke Ozawa, Shinya Honda, Yutaka Matsubara, Hiroaki Takada, Toshikazu Kato, Hitoshi Yamamoto
IPSJ EMB-48, No.2, pp.1-8, Minato, Tokyo
Link
-
2018 Domestic Real-time
Performance Evaluation of SOME/IP and DDS for Next-Generation In-Vehicle Systems Taiki Mizutani, Yutaka Matsubara, Hiroaki Takada
IPSJ Research Report 2018-EMB-47 No.5, Oki, pp.1-6
Link
-
2018 Poster Real-timeVerification
Multi-task CFI Using Arm TrustZone for Armv8-M Tomoaki Kawada, Shinya Honda, Yutaka Matsubara, Hiroaki Takada
SWEST20, Gero
-
2017 Journal Real-time
IXM: Rapid Inter-Process Communication Middleware for Robotics Software Midori Sugaya, Yutaka Matsubara, Takuma Sumiya, Miyuki Nakano
IPSJ Journal, Vol.58, No.10, pp.1578-1590
This paper presents IXM, a fast inter-process communication middleware designed for robot control software. By reducing copying and overhead in message exchange, it keeps the delay between sensing and actuation small.
Link
-
2017 Journal Real-time
EV3RT: A Real-time Software Platform for LEGO Mindstorms EV3 Yixiao Li, Yutaka Matsubara, Hiroaki Takada
Computer Software, Vol.34, Issue 4, pp.4_91-4_115
This paper presents EV3RT, a real-time software platform that lets developers run RTOS-based applications on the LEGO Mindstorms EV3 robot kit. It brings the TOPPERS RTOS to the EV3 hardware together with device support and a development environment. The platform is widely used in embedded systems education and robot contests.
Link
-
2017 Intl. conf. VerificationReal-time
IDHCC: A Security-Enhanced ID Hopping CAN Controller Design to Guarantee Real-Time Wufei Wu, Ryo Kurachi, Gang Zeng, Yutaka Matsubara, Hiroaki Takada, Renfa Li
CERTS 2017, pp.14-21, Jun 2017
This paper designs IDHCC, a CAN controller that hops message IDs for security while guaranteeing real-time message delivery. The controller changes IDs in a way both sender and receiver can follow, so protection is added without breaking communication. This design study preceded the extended IDH-CAN journal version.
Link
-
2017 Domestic (reviewed) Real-time
Energy-Efficient Allocation of Periodic Real-Time Tasks for Heterogeneous Systems by Execution Variance Yang Qin, Gang Zeng, Ryo Kurachi, Yutaka Matsubara, Hiroaki Takada
ESS 2017 WiP, Gero
Link
-
2017 Domestic Real-time
Performance Evaluation of Service-Oriented Middleware SOME/IP-SD for Next-Generation Automotive Systems Taiki Mizutani, Yutaka Matsubara, Hiroaki Takada
IPSJ Research Report 2017-EMB-44 No.5, Okinawa, pp.1-6
Link
-
2016 Article VerificationReal-time
Security and Safety of In-Vehicle Devices Ryo Kurachi, Yutaka Matsubara, Hiroaki Takada
IPSJ Magazine, Vol.57, No.7
A review article explaining the relationship between security and functional safety for in-vehicle devices. It shows that a cyber attack can break the assumptions behind safety design, so security measures must be planned as part of functional safety. Basic attack examples and defense concepts are introduced for non-specialists.
-
2016 Journal VerificationReal-time
CaCAN: Centralized Authentication System in CAN Ryo Kurachi, Yutaka Matsubara, Hiroaki Takada, Hiroshi Ueda, Satoshi Horihata
IEICE Transactions, Vol.J99-A No.2, pp.118-130
This paper proposes CaCAN, a system in which a central monitor node authenticates messages on the CAN in-vehicle network and removes unauthorized ones. The monitor node checks message authentication codes and neutralizes unauthorized frames before they take effect. Requiring only one added node makes the scheme easy to introduce, and this is the extended journal version of the escar 2014 paper.
-
2016 Journal Real-time
Energy-aware Task Migration for Multiprocessor Real-time Systems Gang Zeng, Yutaka Matsubara, Hiroyuki Tomiyama, Hiroaki Takada
Future Generation Computer Systems, Vol.56, pp.220-228
This paper proposes moving tasks between processors at run time to reduce energy consumption in multiprocessor real-time systems while meeting deadlines. Migration decisions compare the cost of moving a task with the energy saved by balancing load across processors. This is the extended journal version of the authors' ICESS 2014 conference paper.
Link
-
2016 Intl. conf. Real-time
An Evaluation Framework of OS-level Power Managements for the big.LITTLE Architecture Hideki Takase, Kazumi Aono, Yutaka Matsubara, Kazuyoshi Takagi, Naofumi Takagi
2016 14th IEEE International New Circuits and Systems Conference (NEWCAS 2016), Vancouver, Jun 2016
This paper presents a framework for evaluating OS-level power management schemes on the big.LITTLE architecture, which combines fast and efficient cores. The framework runs different power management policies under the same conditions so their energy and performance can be compared fairly. Such comparisons guide OS design for energy-sensitive devices.
Link
-
2016 Domestic Real-time
Past and Future of the enPiT Project at Nagoya University Nobuyuki Tachi, Norihiro Yoshida, Masaki Yamamoto, Tomoaki Unagami, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Research Report 2016-EMB-043 No.2, Kyushu University, pp.1-2
-
2016 Domestic Real-time
Development of a TCP/IP Protocol Stack for In-Vehicle Networks Kazuki Honda, Yutaka Matsubara, Hiroaki Takada
IPSJ Research Report 2016-EMB-40 No.2, Goto
Link
-
2016 Domestic Real-time
IXM: Process Communication Middleware for Robot Control Software Takuma Sumiya, Yutaka Matsubara, Midori Sugaya
IPSJ Research Report 2016-EMB-40 No.5, Goto
-
2016 Domestic Real-time
Efficient Data Sharing Communication with Protection on Robot Middleware Takuma Sumiya, Midori Sugaya, Yutaka Matsubara, Miyuki Nakano
The 60th Annual Conference of the Institute of Systems, Control and Information Engineers (SCI'16), May 2016
-
2016 Poster Real-time
Research Activities for Automotive Ethernet Network Keigo Kawahara, Masato Sato, Katsunori Aoki, Yutaka Matsubara, Hiroaki Takada
Automotive Ethernet Congress 2016, Munich
-
2015 Intl. conf. Real-time
A Mobile Robot for Fall Detection for Elderly-Care Takuma Sumiya, Yutaka Matsubara, Miyuki Nakano, Midori Sugaya
KES 2015, Vol.60, pp.870-880, Singapore, Sep 2015
This paper presents a mobile robot system that detects falls of elderly people to support care services. A mobile robot can move to check on a person, complementing fixed sensors that cover only part of a home. Combining sensing and robot technology aims to reduce the burden of watching over elderly people.
Invited paper.
Link
-
2015 Domestic (reviewed) Award Real-time
Evaluation Environment for Power Management Methods on Heterogeneous Multicore Systems Kazumi Aono, Hideki Takase, Yutaka Matsubara, Kazuyoshi Takagi, Naofumi Takagi
ESS 2015, Tokyo
Student Encouragement Award.
-
2015 Domestic Real-time
Fast and Accurate Estimation of Instruction Cycles for ARM Architecture Tsuyoshi Sato, Hiroaki Takada, Shinya Honda, Yutaka Matsubara
Design Gaia 2015, Nagasaki
-
2015 Domestic Real-time
Study on Power Saving for a Monitoring Robot Takanori Nagamine, Yutaka Matsubara, Midori Sugaya
IPSJ 77th National Convention, Kyoto
-
2015 Award Real-time
Student Encouragement Award for Evaluation Environment of Power Management on Heterogeneous Multicore Systems (awarded Oct 2015) Kazumi Aono, Hideki Takase, Yutaka Matsubara, Kazuyoshi Takagi, Naofumi Takagi
ESS 2015
-
2014 Intl. conf. VerificationReal-time
CaCAN - Centralized Authentication System in CAN Ryo Kurachi, Yutaka Matsubara, Hiroaki Takada, Naoki Adachi, Yukihiro Miyashita, Satoshi Horihata
Proceedings of the escar 2014 Europe, pp. 1-9, Hamburg, Nov 2014
This paper presents CaCAN, a centralized message authentication system for the CAN in-vehicle network, at the automotive security conference escar. A monitor node authenticates messages on the bus and neutralizes unauthorized ones, requiring little change to existing vehicle networks. This work was later extended into the journal version.
Link
-
2014 Intl. conf. Real-time
A Simulation Environment and Preliminary Evaluation for Automotive CAN-Ethernet AVB Networks Keigo Kawahara, Yutaka Matsubara, Hiroaki Takada
Proceedings of the 1st OMNeT++ Community Summit, pp.xx-xx, Hamburg, Sep 2014
This paper builds a simulation environment for automotive networks combining CAN and Ethernet AVB, and reports a preliminary evaluation. The model reproduces how time-sensitive traffic flows across the two network types, so designs can be examined before building hardware.
Link
-
2014 Intl. conf. Real-time
Task Migration for Energy Saving in Real-Time Multiprocessor Systems Gang Zeng, Yutaka Matsubara, Hiroyuki Tomiyama, Hiroaki Takada
Proceedings of the 11th IEEE International Conference on Embedded Software and Systems (ICESS 2014), Paris, Aug 2014
This paper proposes migrating tasks between processors to save energy in real-time multiprocessor systems while keeping deadlines. Moving tasks at run time balances load, so processors can run at lower speeds and consume less energy while deadlines are still met. This work formed the basis of the later journal version.
Link
-
2014 Intl. conf. Real-time
A Platform for LEGO Mindstorms EV3 Based on an RTOS with MMU Support Yixiao Li, Takuya Ishikawa, Yutaka Matsubara, Hiroaki Takada
OSPERT 2014, pp.51-59, Madrid, Jul 2014
This paper presents a software platform for the LEGO Mindstorms EV3 robot kit based on an RTOS with memory protection (MMU) support. Memory protection via the MMU keeps a faulty program from corrupting the rest of the system, which is unusual for hobby-class robot kits. This platform later evolved into EV3RT.
Link
-
2014 Domestic (reviewed) VerificationReal-time
Research and Development of a Security-Oriented Software Platform for Next-Generation Vehicles and Service Robots Koichi Goto, Hiroyuki Hattori, Ayumu Sugiyama, Hiroaki Hara, Hiroaki Takada, Yutaka Matsubara, Daichi Mizuguchi, Koichi Takahashi
WOCS2 2014, Tokyo
-
2014 Domestic (reviewed) Real-time
Supporting Real-Time Processing and Power Saving with Multicore-Based Robot Middleware Takuma Sumiya, Yutaka Matsubara, Miyuki Nakano, Midori Sugaya
ComSys 2014, Toyosu
-
2014 Domestic Real-time
Extended ARINC 653 Scheduling Algorithm for Highly Responsive Real-Time Application Integration Yuichi Sato, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Research Report 2014-EMB-32 No.3, Ishigaki, pp.1-6
Link
-
2014 Domestic Real-time
Report on LED-Camp1 Short-Term Training for Young Embedded Engineers Hideki Takase, Shintaro Hosoai, Tomoyuki Ando, Yukiyo Owashi, Tatsuya Kawakami, Nobuyuki Tachi, Toshio Hoshino, Yutaka Matsubara, Seiko Akayama, Kenji Hisazumi, Hiroaki Takada
IPSJ Research Report 2014-EMB-32 No.36, Ishigaki, pp.1-6
-
2014 Domestic Real-time
An RTOS-based Platform for LEGO Mindstorms EV3 Yixiao Li, Takuya Ishikawa, Yutaka Matsubara, Hiroaki Takada
165th SLDM and 32nd EMB Joint Workshop (ETNET 2014), Ishigaki
-
2014 Poster Real-time
Supporting Real-Time Processing and Power Saving with Multicore-Based Robot Middleware Takuma Sumiya, Yutaka Matsubara, Miyuki Nakano, Midori Sugaya
ComSys 2014, Toyosu
-
2014 Poster Real-time
Robot Middleware Supporting Real-Time Processing and Power Saving Takuma Sumiya, Takanori Nagamine, Yutaka Matsubara, Midori Sugaya
SWEST16 Proceedings, Gifu
-
2014 Poster Real-time
Latest Status of the TOPPERS Project Yutaka Matsubara
SWEST16 Proceedings, Gifu
-
2014 Poster Real-time
Visualization of the Embedded Data Stream Management System eDSMS Masaki Nakai, Yutaka Matsubara, Hiroaki Takada, Akihiro Yamaguchi
SWEST16 Proceedings, Gifu
-
2014 Poster Award Real-time
Simulation Environment for Mixed CAN-Ethernet AVB Networks Using OMNeT++ Keigo Kawahara, Yutaka Matsubara, Hiroaki Takada
SWEST16 Proceedings, Gifu
Best Poster Student Presentation Award.
-
2014 Award Real-time
Best Poster Student Presentation Award for OMNeT++ Simulation Environment for Mixed CAN-Ethernet AVB Networks (awarded Aug 2014) Keigo Kawahara, Yutaka Matsubara, Hiroaki Takada
SWEST 16
-
2013 Journal Real-timeVerification
Safety Measures for Software Faults in Embedded Systems Yutaka Matsubara, Hiroaki Takada
Computer Software, Vol.30, No.1, pp.119-129
This paper organizes and discusses safety measures against software faults in embedded systems, such as detecting failures and keeping the system in a safe state. Since testing cannot remove every fault, systems should detect anomalies at run time and move to a safe state before harm occurs. The paper organizes concrete techniques usable in resource-limited embedded systems.
-
2013 Intl. conf. Real-time
A Simulation Environment Based on OMNeT++ for Automotive CAN-Ethernet Networks Jun Matsumura, Yutaka Matsubara, Hiroaki Takada, Masaya Oi, Masumi Toyoshima, Akihito Iwai
WATERS 2013, pp.1-6, Paris, Jul 2013
This paper presents a simulation environment based on the OMNeT++ network simulator for automotive networks that combine CAN and Ethernet. Mixed CAN-Ethernet designs were emerging in vehicles, and the environment lets engineers evaluate such network designs on a computer. Communication design can thus be examined without a real car.
Link
-
2013 Domestic Real-time
Evaluation of a Hierarchical Scheduling Algorithm with Overhead-Aware Simulation Yuichi Sato, Yutaka Matsubara, Hiroaki Takada
IPSJ Research Report 2013-EMB-31, Tokyo
-
2013 Domestic Real-time
CAN-Ethernet Protocol Conversion Algorithm for In-Vehicle Networks Jun Matsumura, Yutaka Matsubara, Hiroaki Takada, Masaya Oi, Masumi Toyoshima, Akihito Iwai
ETNET 2013, Tsushima
-
2013 Domestic Real-time
Schedulability Evaluation of a FIFO Preemptive Synchronization Protocol for Multicore Systems Takahiro Fujitani, Yutaka Matsubara, Shinpei Kato, Hiroaki Takada
IPSJ Research Report 2012-OS-124, Okayama
-
2013 Domestic Real-time
An Indoor Mobile Robot Remote Control System Using a Smartphone Kanata Kususe, Kohei Kawai, Hideki Shimada, Kenya Sato, Yutaka Matsubara, Shinya Honda
Forum on Information Technology (FIT2013), Vol.12, No.1, pp.313-314, 2013
-
2013 Poster Real-time
Evaluation of an Integrated Algorithm Using an Overhead-Aware Scheduling Simulator Yuichi Sato, Yutaka Matsubara, Hiroaki Takada
SWEST15 Proceedings, Gifu
-
2012 Journal Real-time
schesim: Scheduling Simulator for Real-Time Applications Yasumasa Sano, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IEICE Transactions D, Vol.J95-D No.12, pp.2008-2020
This paper presents schesim, a simulator that reproduces how a real-time scheduler runs application tasks, so that timing behavior can be checked before deployment. Developers describe their tasks and scheduling policies, and the simulator shows whether deadlines are met under various conditions. This lets timing behavior be examined without preparing target hardware.
-
2012 Intl. conf. Real-time
An Open-Source Flexible Scheduling Simulator for Real-time Applications Yutaka Matsubara, Yasumasa Sano, Shinya Honda, Hiroaki Takada
ISORC 2012, pp.16-22, Shenzhen, Jun 2012
This paper presents an open-source simulator that flexibly models schedulers and real-time applications to evaluate timing behavior. Being open source, the simulator can be extended with new scheduling algorithms and reused freely in research and education.
Link
-
2011 Journal Real-time
Practice of a Summer School on Embedded System Technologies by Students and Young Engineers Ittetsu Taniguchi, Yuki Ando, Hideki Takase, Takuya Azumi, Yutaka Matsubara, Shintaro Hosoai, Yasuaki Murakami, Midori Sugaya
IPSJ Journal, Vol.52, No.12, pp.3221-3237
This paper reports the practice and outcomes of a summer school on embedded system technologies organized by students and young engineers. Participants design and build an embedded system in a short period, while the young organizers themselves grow by planning and running the school. The paper analyzes the educational effects observed through this practice.
-
2011 Journal Real-time
Probabilistic Analysis of Response Time Considering Initial Phase Distribution of Periodic Tasks Takuya Ishikawa, Yutaka Matsubara, Hiroaki Takada
IPSJ Journal, Vol.52, No.12, pp.3192-3204
This paper analyzes the response time of periodic tasks probabilistically, taking into account the distribution of their initial phases (start offsets). Worst-case analysis alone is often too pessimistic, and the probabilistic view estimates how likely each response time actually is.
-
2011 Journal Real-time
Hierarchical Scheduling Algorithm with Task Start Delay for Time Protection Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Journal, Vol.52, No.8, pp.2387-2401
This paper proposes a hierarchical scheduling algorithm with task start delay that provides time protection, preventing one application from stealing CPU time from others. Deliberately delaying certain task starts makes each application's CPU budget easier to guarantee within the hierarchical scheduler.
-
2011 Journal Real-time
Interruptible Priority-Inheritance Spin Lock and Its Hardware Implementation Toshiyuki Ichiba, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ ACS, Vol.4, No.3, pp.133-146
This paper proposes a spin lock with priority inheritance that can be interrupted, and implements it in hardware to reduce blocking in multiprocessor real-time systems. Ordinary spin locks can delay interrupts and urgent tasks while waiting, and the proposed lock avoids this by allowing interruption and inheriting priority. A hardware implementation keeps the overhead of the mechanism low.
-
2011 Domestic (reviewed) Award Real-time
Scheduling Simulator for Real-Time Applications with User-Defined Task Processing Yasumasa Sano, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
ESS 2011 Proceedings, Tokyo
Excellent Paper Award.
Link
-
2011 Domestic Real-time
Scheduling Simulator with User-Defined Task Processing for Real-Time Applications Yasumasa Sano, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
ETNET 2011, Miyakojima
-
2011 Poster Real-time
Scheduling Simulator with User-Defined Task Processing for Real-Time Applications Yasumasa Sano, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
SWEST13 Proceedings, Gifu
-
2011 Thesis Real-time
Hierarchical Scheduling for Integrating Embedded Real-Time Applications Yutaka Matsubara
Doctoral Dissertation
Recommended by IPSJ SIGEMB.
-
2011 Thesis Real-time
Recommended Doctoral Thesis Digest Yutaka Matsubara
IPSJ SIGEMB recommended thesis announcement
-
2011 Award Real-time
Excellent Paper Award for Scheduling Simulator with User-Defined Task Processing (awarded Oct 2011) Yasumasa Sano, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Embedded System Symposium 2011
-
2010 Domestic (reviewed) Real-time
Hardware Implementation and Evaluation of an Interruptible Queueing Spin Lock Toshiyuki Ichiba, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
ESS 2010, Tokyo
-
2010 Domestic Real-timeVerification
Hierarchical Scheduling Algorithm with Task Start Delay for Time Protection Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Research Report 2010-EMB-19, Kumamoto
-
2010 Domestic Real-time
Probabilistic Analysis of Response Time in End-to-End Processing of Distributed Real-Time Systems Takuya Ishikawa, Yutaka Matsubara, Hiroaki Takada
IPSJ Research Report 2010-EMB-18, Hakodate
Link
-
2010 Domestic Real-time
Middleware for Communication Between Heterogeneous OSs in Integrated Automotive ECUs Ken Ishitani, Fumio Yamazaki, Takuya Nagao, Masahiro Yamada, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Research Report 2010-EMB-17 No.8, Tokyo
Link
-
2010 Domestic Real-time
DUOS: RTOS Framework for Integrated Automotive ECUs Takuya Nagao, Fumio Yamazaki, Masahiro Yamada, Ken Ishitani, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Research Report 2010-EMB-17 No.8, Tokyo
Link
-
2010 Domestic Real-time
Hardware Implementation and Evaluation of an Interruptible Queueing Spin Lock Toshiyuki Ichiba, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
ETNET 2010, Hachijojima
-
2010 Domestic Real-timeVerification
Time-Protection Scheduling Algorithm Using Only Task Deadlines Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Research Report 2010-EMB-15 No.8, Yokohama
Link
-
2010 Poster Real-time
Development of a Two-Wheel Inverted Pendulum Robot Control System Using a Time-Protection OS Nozomi Kato, Yutaka Matsubara, Shinya Honda, Hiroaki Takada
2nd NCES Symposium, Nagoya
-
2009 Intl. conf. Real-time
Hierarchical Scheduling for Integrating Real-time Applications with Interrupt Routines Yutaka Matsubara, Shinya Honda, Hiroaki Takada
ISOCC 2009, pp.384-387, Busan, Nov 2009
This paper proposes hierarchical scheduling that integrates multiple real-time applications while properly accounting for interrupt routines. Interrupt handling consumes CPU time at unpredictable moments, so the scheduler treats its influence explicitly when guaranteeing each application's share.
Invited paper.
Link
-
2009 Intl. conf. Real-time
History of Summer School on Embedded System Technologies Organized by Students and Young Engineers Hideki Takase, Takuya Azumi, Ittetsu Taniguchi, Yutaka Matsubara, Hayato Kanai, Shintaro Hosoai, Midori Sugaya
WESE 2009, pp.19-26, Grenoble, Oct 2009
This paper reports the history and lessons of a summer school on embedded system technologies organized by students and young engineers in Japan. It looks back on how the peer-run format developed and what kept participants engaged.
Link
-
2009 Domestic Real-time
Hierarchical Scheduling for Integrating Real-Time Applications with Interrupt Routines Yutaka Matsubara, Shinya Honda, Hiroaki Takada
IPSJ Research Report 2009-EMB-14 No.7, Nagoya
-
2008 Journal Real-time
Flexible Scheduling Framework for Integrating Real-Time Applications Yutaka Matsubara, Shinya Honda, Hiroyuki Tomiyama, Hiroaki Takada
IPSJ Journal Embedded Systems Special Issue, Vol.49, No.10, pp.3508-3519
This paper presents a flexible scheduling framework that lets multiple real-time applications with different scheduling needs run together on one system. Each application keeps its own scheduling policy while the framework arbitrates CPU time among them. This eases integrating software components that were developed separately.
-
2008 Domestic Real-time
Time-Protection Scheduling Algorithm Considering Task Priority Yutaka Matsubara, Shinya Honda, Hiroyuki Tomiyama, Hiroaki Takada
IEICE Technical Report on Computer Systems, Vol.107, No.558, Yakushima, pp.173-178
Link
-
2008 Award Real-time
FY2007 Computer Science Area Encouragement Award for Flexible Scheduling Framework for Integrating OSEK Applications (awarded Oct 2008) Yutaka Matsubara, Shinya Honda, Hiroyuki Tomiyama, Hiroaki Takada
IPSJ
-
2008 Award Real-time
TOPPERS of the Year 2008 for Automotive RTOS with Memory and Time Protection (awarded Jun 2008) Hiroyuki Hattori, Shuichi Onishi, Ayumu Kataoka, Yutaka Matsubara, Hiroaki Takada
TOPPERS Project
-
2008 Award Real-time
IP Excellence Award for Open-Source Protected OS: Automotive RTOS with Memory and Time Protection (awarded Apr 2008) Hiroyuki Hattori, Shuichi Onishi, Ayumu Kataoka, Yutaka Matsubara, Hiroaki Takada
10th LSI IP Design Award
-
2007 Journal Real-time
Real-Time Scheduling Algorithm for Time Protection Yutaka Matsubara, Shinya Honda, Hiroyuki Tomiyama, Hiroaki Takada
IPSJ ACS, Vol.48 SIG8(ACS18), pp.192-202
This paper proposes a real-time scheduling algorithm that provides time protection, guaranteeing each application its share of CPU time even if another misbehaves. The scheduler enforces a CPU budget for each application, so a fault in one cannot starve the others. This idea underpins safely consolidating multiple functions onto one processor.
-
2007 Intl. conf. Real-time
SSEST: Summer School on Embedded System Technologies Yutaka Matsubara, Midori Sugaya, Ittetsu Taniguchi, Yasuaki Murakami, Hayato Kanai, Hiroaki Takada
APESER 2007, pp.1-8, Hsinchu, Dec 2007
This paper introduces SSEST, a summer school on embedded system technologies run by students and young engineers, and its educational approach. Participants team up to develop an embedded system in a short period, experiencing the process from design to demonstration. The paper shares the curriculum and how the school is run, so similar programs can be built elsewhere.
Link
-
2007 Domestic (reviewed) Award Real-time
Flexible Scheduling Framework for Integrating OSEK Applications Yutaka Matsubara, Shinya Honda, Hiroyuki Tomiyama, Hiroaki Takada
Embedded System Symposium 2007, pp.33-41
Computer Science Area Encouragement Award (2007).
Link
-
2006 Poster Real-time
Second Summer School on Embedded System Technologies (SSEST2) Yutaka Matsubara, Tetsuya Oda, Hayato Kanai, Ittetsu Taniguchi, Toshikazu Nakano, Atsushi Noda, Takeo Mimura, Yasuaki Murakami
SWEST8 Proceedings, Hamamatsu, pp.107-109
-
2005 Domestic (reviewed) Real-time
Time-Protection Environment for Automotive Control Systems with a Hierarchical Scheduler Yutaka Matsubara, Hiroyuki Tomiyama, Hiroaki Takada
Embedded Software Symposium 2005 Proceedings, pp.110-116
-
2005 Poster Real-time
Summer School on Embedded System Technologies (SSEST1) Midori Sugaya, Yohei Imai, Yin Zhongxiang, Masaki Oyama, Ittetsu Taniguchi, Hiroaki Tanizaki, Chaiwat Sathawornwichit, Atsushi Noda, Yutaka Matsubara, Hirotaka Motodai
SWEST7 Proceedings, Hamamatsu, pp.120-121